Hardware & Software
Hand Gesture Controlled Robot
Project Overview
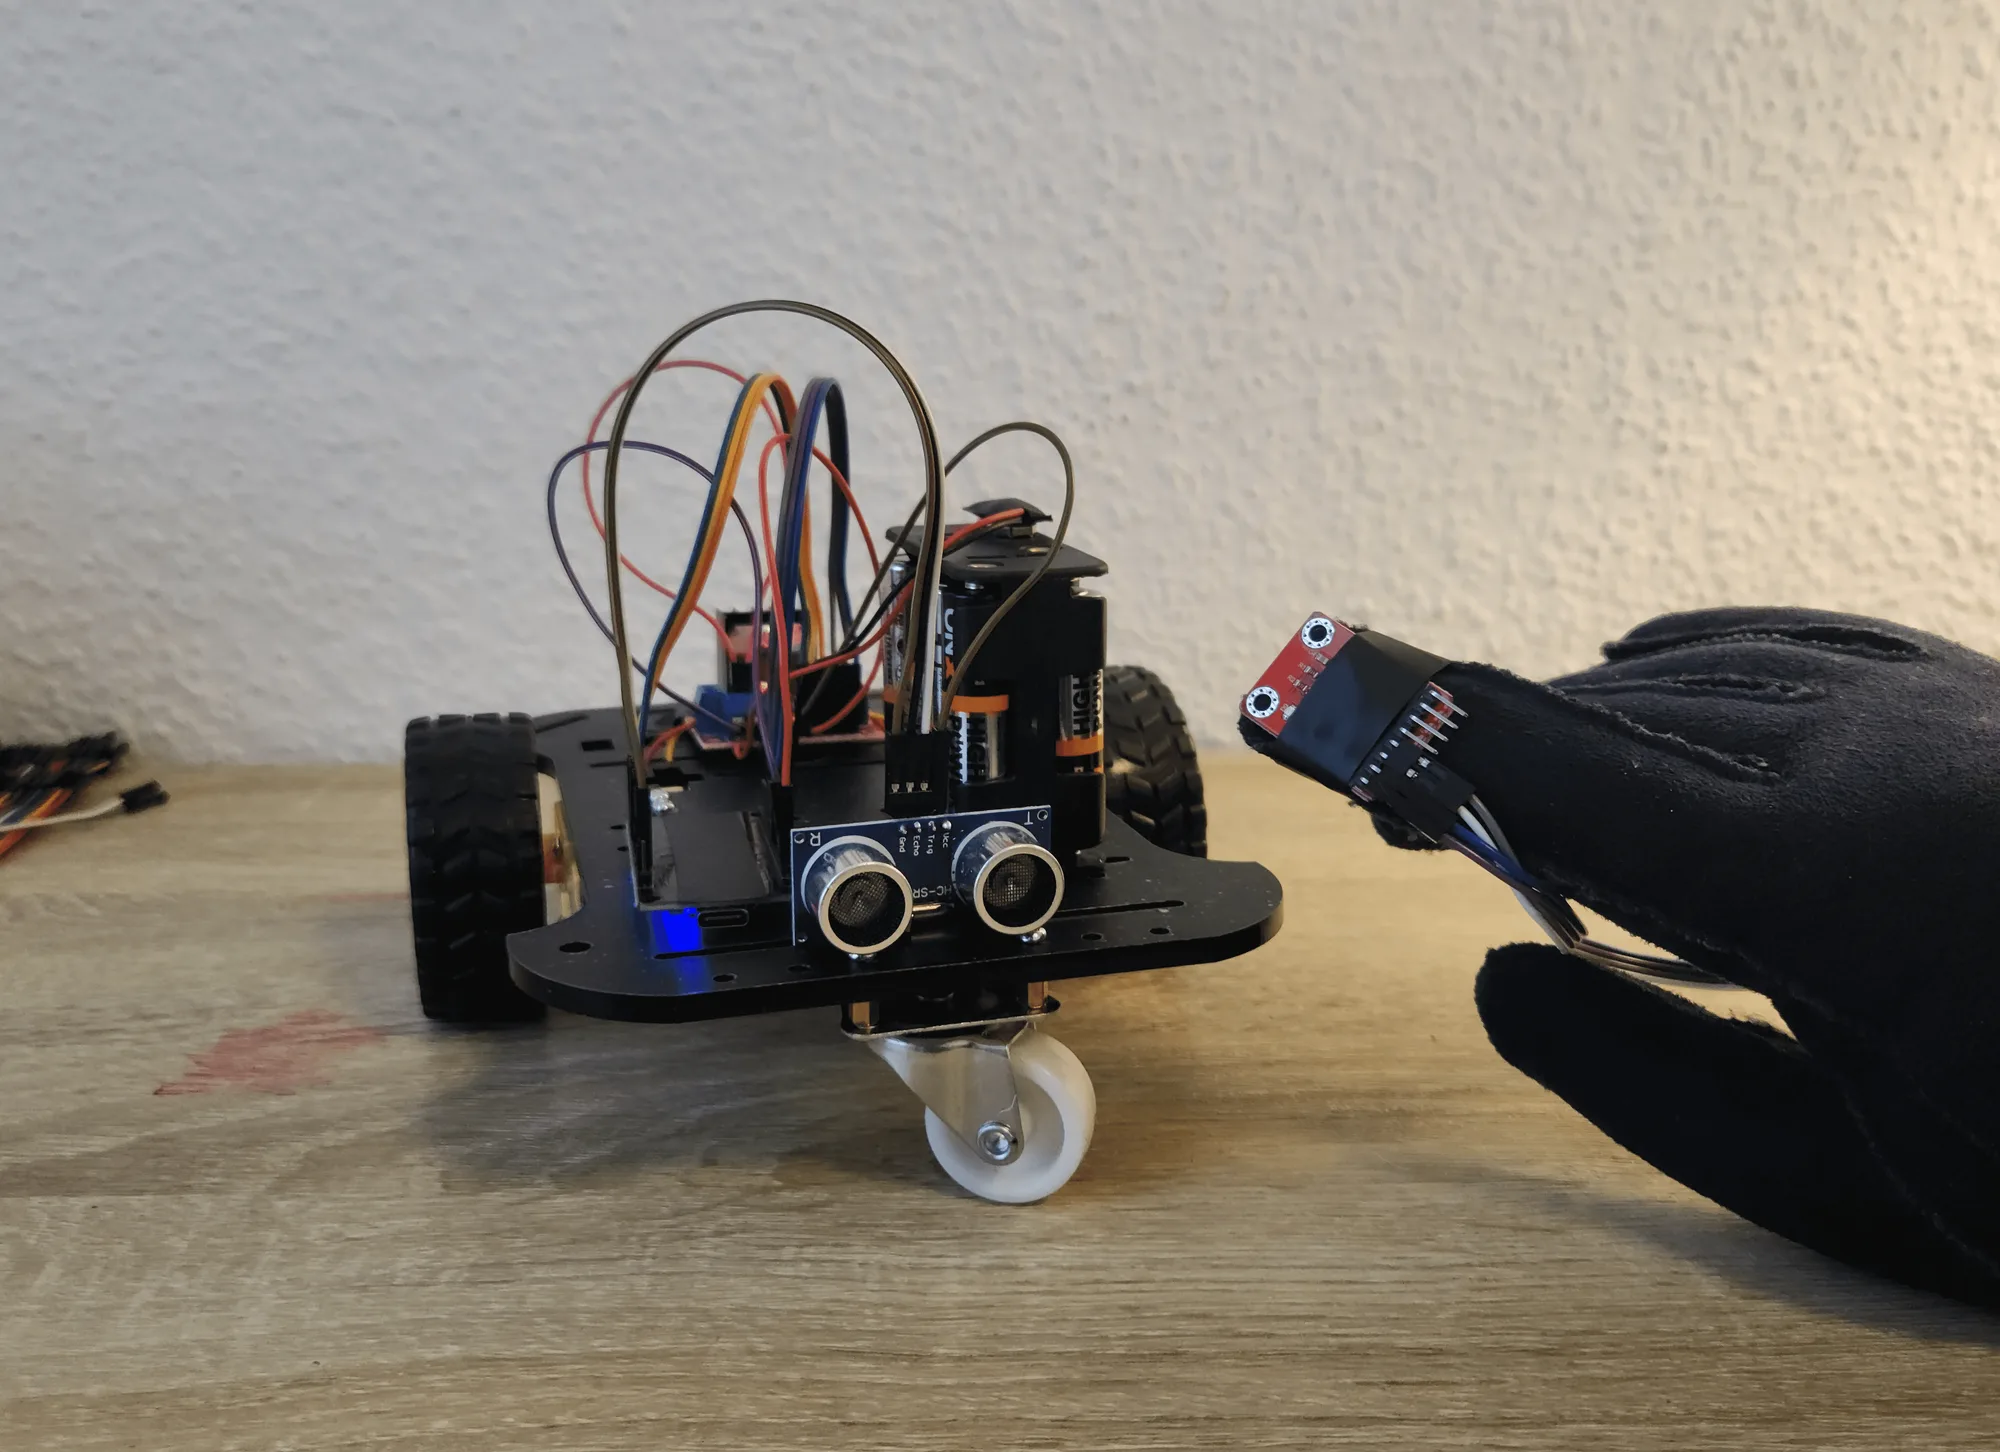
A robot controlled by hand gestures, using an MPU6050 accelerometer and gyroscope mounted on a glove. Tilting the hand in different directions sends movement commands wirelessly to the robot over ESP-NOW.
System Specifications
Two ESP32s, one on the glove and one on the robot. The robot's ESP32 drives two DC motors through an L298N motor driver, with an HC-SR04 ultrasonic sensor on the front and 8 AA batteries, 12V in total.
| Component | Qty | Details |
|---|---|---|
| ESP32 NodeMCU, glove | 1 | Reads the MPU6050 and sends gesture commands to the robot |
| MPU6050 | 1 | 6-axis accelerometer and gyroscope, detects hand tilt |
| Winter glove | 1 | The wearable base that holds the glove's components |
| ESP32 NodeMCU, robot | 1 | Receives gesture commands and controls the motors |
| L298N motor driver | 1 | Dual H-bridge, drives both DC motors |
| DC hobby motors | 2 | Move the robot on a 2WD chassis |
| HC-SR04 ultrasonic sensor | 1 | Front mounted, stops forward movement near obstacles |
| AA batteries | 8 | 12V total, powers the motor driver, ESP32 and sensor |
System Logic and Operation
Logic
Gesture to Motor Command
The MPU6050 sits on the glove's index finger and detects the tilt of the hand. The glove's ESP32 reads it and sends a movement command to the robot's ESP32 over ESP-NOW, which drives the two motors through the L298N.
Gesture Controls
Tilt Up: Move forward.
Tilt Down: Move backward.
Tilt Left: Pivot left.
Tilt Right: Pivot right.
Neutral (Flat): Stop.
Scope and Limitations
Securing the ESP32 to the glove is still a challenge: double sided tape was not strong enough. The future improvement listed is a second HC-SR04 at the back of the robot, for backward obstacle detection.
Safety Features
Two safeguards stop the robot on their own.
Heartbeat: The glove's ESP32 sends a heartbeat every 2 seconds, even when no gesture is being made. If the robot receives nothing for 10 seconds, it stops the motors, so it cannot keep running if the glove is switched off or goes out of range.
Obstacle Detection: The HC-SR04 measures distance continuously during forward movement. If an obstacle is within 20cm, the forward command is ignored and the motors stay stopped until it is cleared.