Hardware, Software & CAD
Sumo Bot
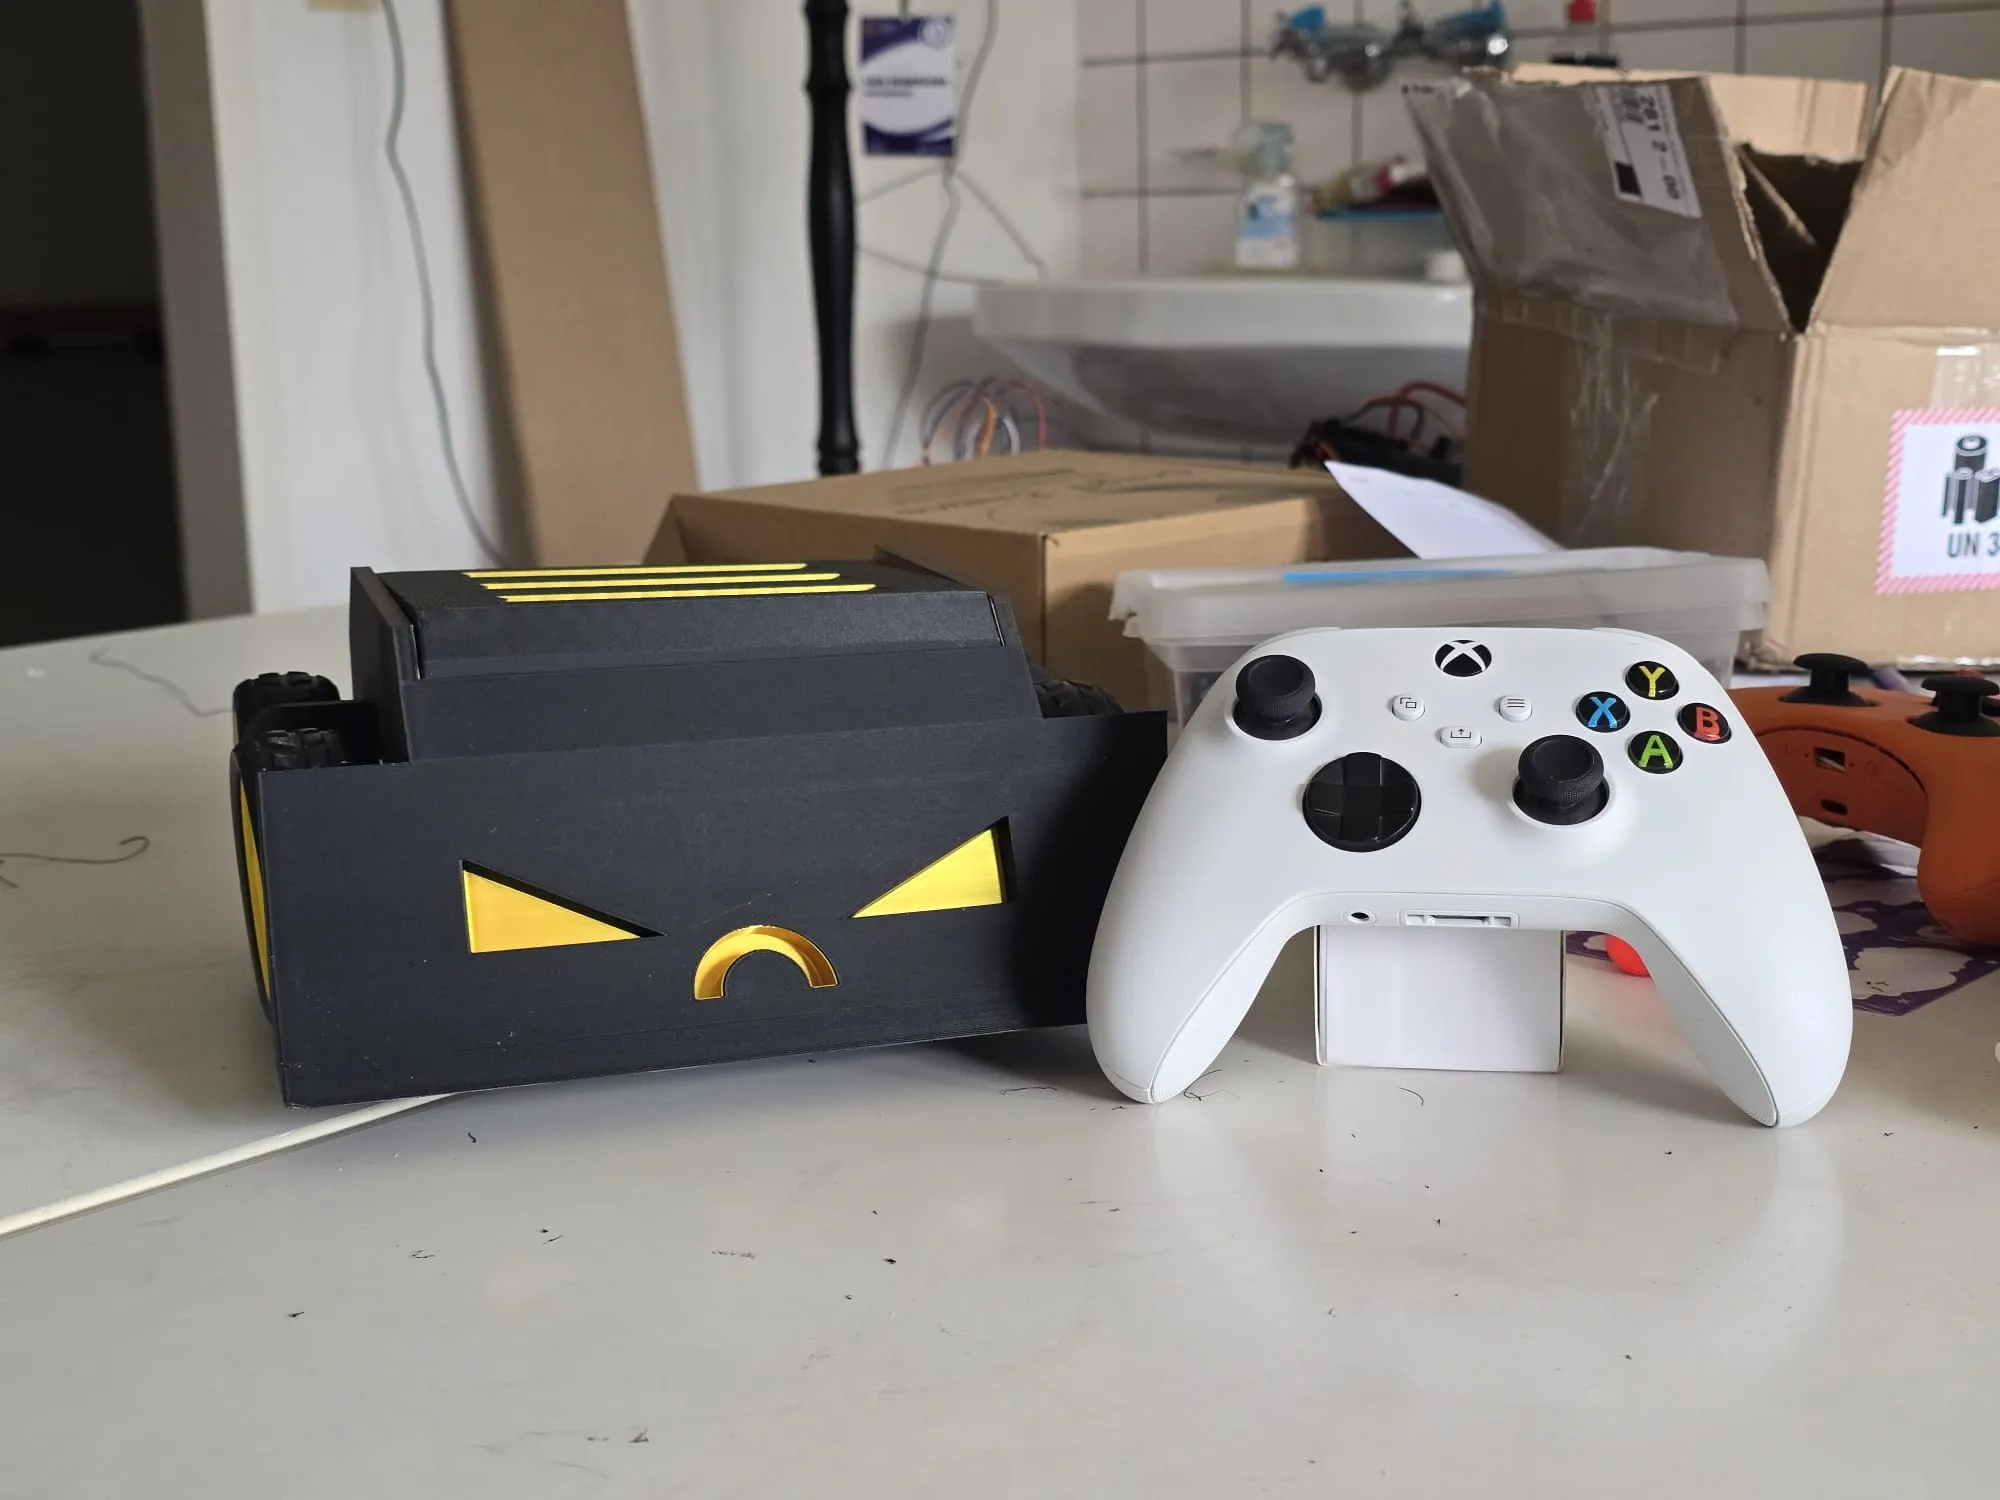
Project Overview
A remote-controlled sumo robot built for a university competition. Designed from scratch: the chassis was modelled in Autodesk Fusion 360, then assembled, wired and programmed by a team of four students.
Built with three teammates. The full team is credited on GitHub.
System Specifications
Built with Autodesk Fusion 360 for the CAD, and C++ in the Arduino IDE for the firmware.
| Component | Qty | Details |
|---|---|---|
| Microcontroller | 1 | ESP32 |
| Controller | 1 | Xbox controller (wireless) |
| Motor controllers | 2 | TB6612FNG |
| Motors | 4 | TT hobby motors |
| Chassis | 1 | Custom, designed in Autodesk Fusion 360 |
| Power supply | 1 | 7.4V LiPo battery |
| Buck converter | 1 | Steps 7.4V down to 5V for the ESP32 and motor controllers |
System Logic and Operation
Logic
Wireless Control
The robot is controlled wirelessly through an Xbox controller connected to an ESP32 microcontroller. The ESP32 receives the controller input and drives the motors accordingly.